Voyis Software
Voyis VSLAM Powered by EIVA NaviSuite
Real-time visual acquisition and 3D reconstruction software for the Discovery Stereo camera, integrated with EIVA NaviSuite.
Description
Voyis VSLAM Powered by EIVA NaviSuite is real-time visual acquisition and visualization software for the Discovery Stereo camera; Voyis provides it exclusively for that camera. It gives ROV operators immediate feedback on survey data quality by building a live textured 3D voxel model during acquisition, which shows coverage gaps as they appear.
Key features
- Live textured 3D voxel model built during acquisition
- Real-time visualization of coverage gaps
- With a connected INS such as a Sonardyne SPRINT-Nav, places the map in a global geodetic frame from mission start
- System controls, low-latency video, survey metrics and the 3D model shown in the EIVA NaviSuite interface
Applications
ROV visual surveys and real-time 3D reconstruction with the Discovery Stereo camera.
More from Voyis
- Voyis Discovery Stereo Inspection Series
- Voyis Observer Vision Series
- Voyis Observer Survey Series Pro
- Voyis Observer Survey Series Micro
- Voyis Insight Nano
- Voyis Insight Micro
- Voyis Insight Pro
- Voyis Recon AUV Payload
- Voyis Recon LS AUV Payload
- Voyis ROV Skid (Small ROV Skid)
- Voyis XL ROV Skid
- Voyis Discovery Stereo Perception Series
Featured products
All products →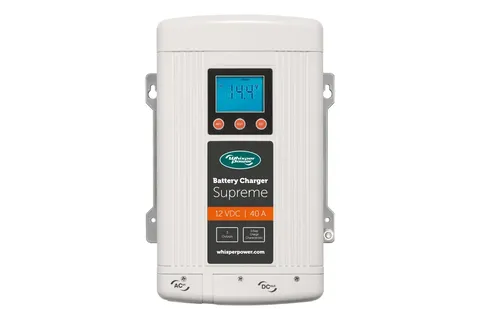
System / Package
Supreme 12 VDC - 40 A
Automatic 12 V, 40 A battery charger with three independent outputs, programmable for AGM, GEL, wet and lithium, universal 90–265 VAC input; CE and ABYC compliant.
Accessory
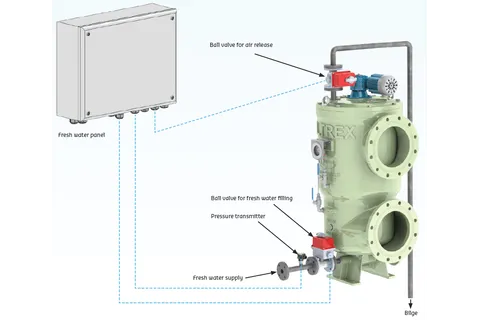
Fresh Water Filling
Automated function that drains sea water from the BWTS filter and refills it with fresh water to stop organisms clogging the mesh.
Equipment
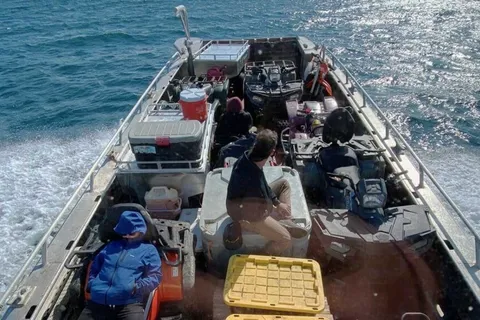
Munson 52′ Series
52 ft welded aluminum landing craft used for military vehicle transport, island development, expedition support and sportfishing.